Robotics & simulation2026
Robopreneur
Built an agent-based robotics simulation in Python and Mesa, with task allocation, battery management, and live performance dashboards in Solara.
Languages
- Python
Frameworks & tools
- Mesa
- Solara
- pandas
- NumPy
- Matplotlib
- Docker
Research in action
RODEO lab demonstration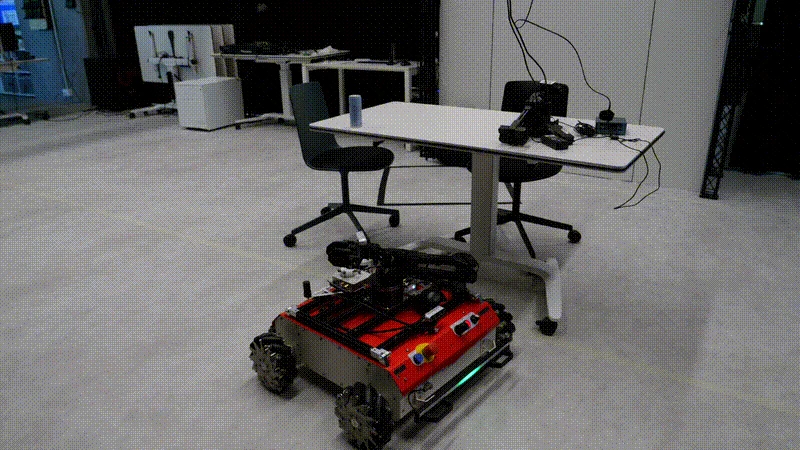
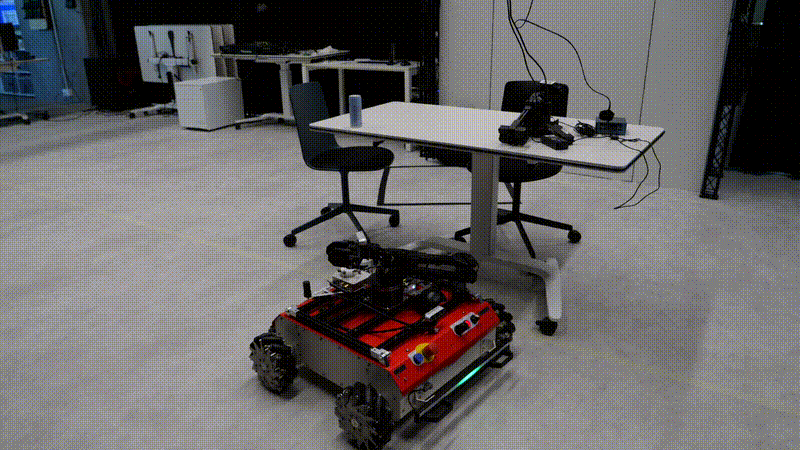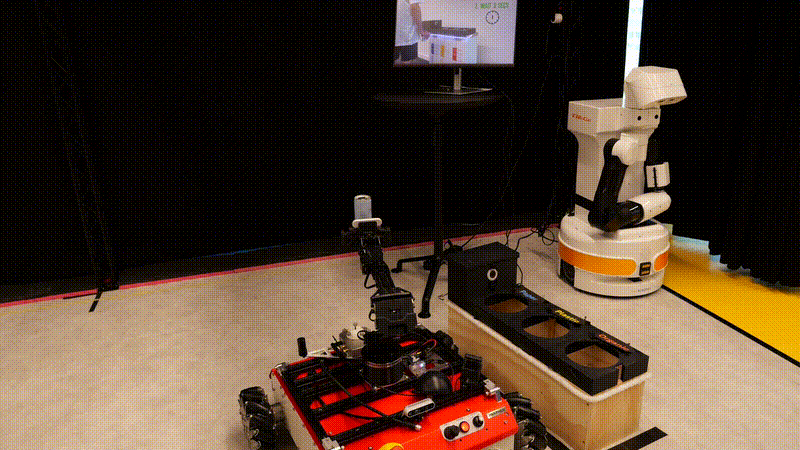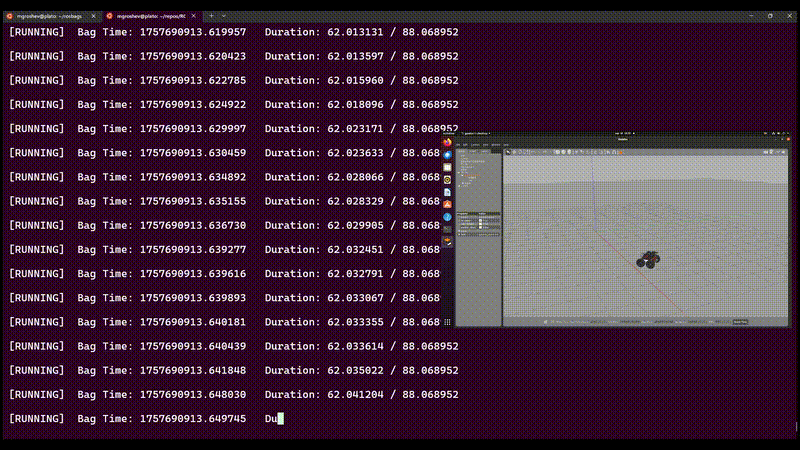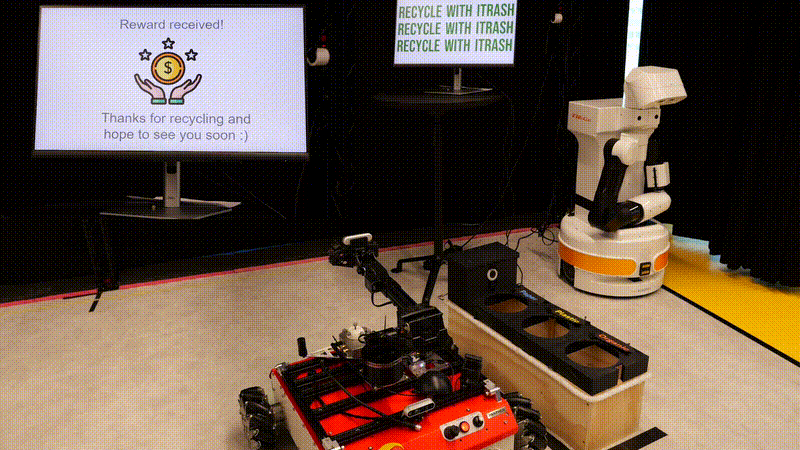
Original RODEO lab demonstration · IE Robotics and AI Lab / Milan Groshev. My contribution is the simulation linked below.
Problem
Service robots must balance task demand, earnings, and battery constraints while sharing work with people. Physical trials make those trade-offs expensive to explore.
Solution
Model robots and humans as agents in a shared service economy: accept eligible tasks, earn rewards, and pay for recharging when batteries run low.
Build
Implemented task queues, work schedules, battery logic, and floor-plan routing in Python/Mesa. Added Solara dashboards, configurable experiment runs, CSV exports, and Docker packaging.
Outcome
An interactive research tool for comparing charging strategies, workloads, and human–robot teams. Tracks task throughput, queue length, wealth distribution, and critical-battery rate.